0.12–0.15 mm RMS
Sub-millimetre Optical Tracking
적외선 기반 광학식 트래킹으로 마커가 부착된 도구와 대상의 3D 위치·방향을 실시간으로 추적합니다. 수술 내비게이션, 로보틱스, 연구 장비 개발처럼 높은 반복성과 정밀도가 필요한 환경에 적합합니다.
Polaris Vega®는 마커가 부착된 tool, probe, rigid body, OEM 장비의 3D 위치와 방향을 실시간으로 추적하는 NDI의 고성능 optical tracking system입니다. 수술 내비게이션, 로보틱스, 방사선 치료, 생체역학 연구, 장비 개발 환경에서 sub-millimetre tracking workflow를 구성할 수 있습니다.
Polaris Vega®는 optical tracker와 optical marker가 함께 작동하는 시스템입니다. tracker가 infrared marker를 인식하고, marker arrangement를 기반으로 tool의 위치와 방향을 계산하여 host software로 전달합니다. 이 데이터는 내비게이션, registration, robot guidance, motion verification, QA workflow의 기준 좌표로 활용됩니다.
상우과학은 Polaris Vega ST, VT, XT 모델 선택부터 passive·active marker 구성, rigid body 설계, tracker 설치 위치, measurement volume, tool calibration, Ethernet communication, software integration까지 목적에 맞춰 검토합니다.
적외선 기반 광학식 트래킹으로 마커가 부착된 도구와 대상의 3D 위치·방향을 실시간으로 추적합니다. 수술 내비게이션, 로보틱스, 연구 장비 개발처럼 높은 반복성과 정밀도가 필요한 환경에 적합합니다.
NDI Passive Spheres™, Polaris Radix™ Lens, Polaris Active Markers 등 다양한 마커 옵션과 결합하여 오염 위험, 시야 확보, 도구 설계, 동적 움직임 조건에 맞는 트래킹 구성을 선택할 수 있습니다.
Pyramid volume과 optional extended pyramid volume을 통해 장비와 작업 대상 사이의 충분한 측정 공간을 확보합니다. 수술실, 연구실, 로봇 실험 환경에서 도구가 움직이는 작업 범위를 고려해 설치할 수 있습니다.
Gigabit Ethernet, TCP communication, built-in API, NDI software utilities를 기반으로 OEM 장비와 연구 시스템에 트래킹 데이터를 통합합니다. 좌표계 설정, tool definition, calibration, diagnostics workflow를 함께 검토합니다.

NDI Polaris Vega®는 적외선 optical tracker와 optical markers를 이용해 도구, 프로브, rigid body, OEM 장비의 3D 위치와 방향을 실시간으로 측정하는 광학식 3D tracking system입니다. 마커가 부착된 도구를 카메라가 인식하고, 각 마커의 공간 좌표를 기반으로 도구의 6D pose를 계산하기 때문에 수술 내비게이션, 영상 유도 시술, 로보틱스, 방사선 치료실, 생체역학 연구, 장비 개발 환경에서 정밀한 위치 기준을 만들 수 있습니다. Polaris Vega 제품군은 ST, VT, XT와 같이 용도별 모델을 제공하며, ST는 다양한 임상·연구 환경에 적합한 versatile tracker, VT는 HD video와 optical tracking을 결합한 AR·machine vision workflow, XT는 high-speed robotics와 responsive control을 위한 premium tracking 구성으로 검토할 수 있습니다.

마커가 부착된 probe, rigid body, surgical instrument, 연구용 tool의 위치와 방향을 추적하여 장비 좌표계와 대상 좌표계 사이의 관계를 계산합니다.

Cygna 6D와 NDI software utility를 활용하면 tool definition, tracking status, coordinate data, diagnostics를 확인하고 OEM 소프트웨어 통합 전 검증할 수 있습니다.
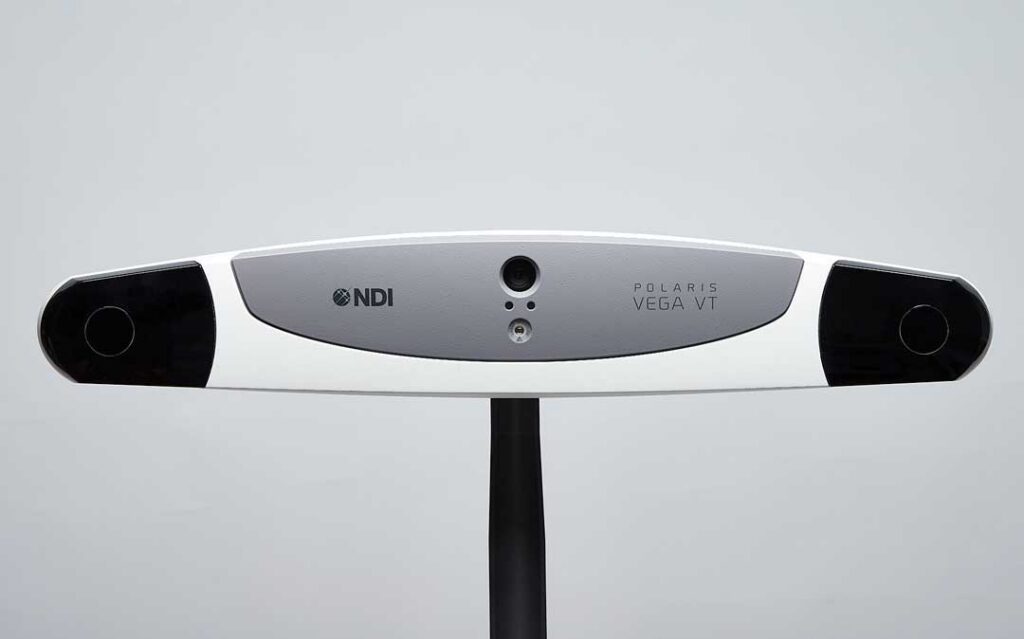
Polaris Vega VT는 optical tracking과 integrated HD video를 결합해 AR visualization, video-enabled navigation, machine vision workflow를 고려하는 OEM 장비 개발에 활용할 수 있습니다.
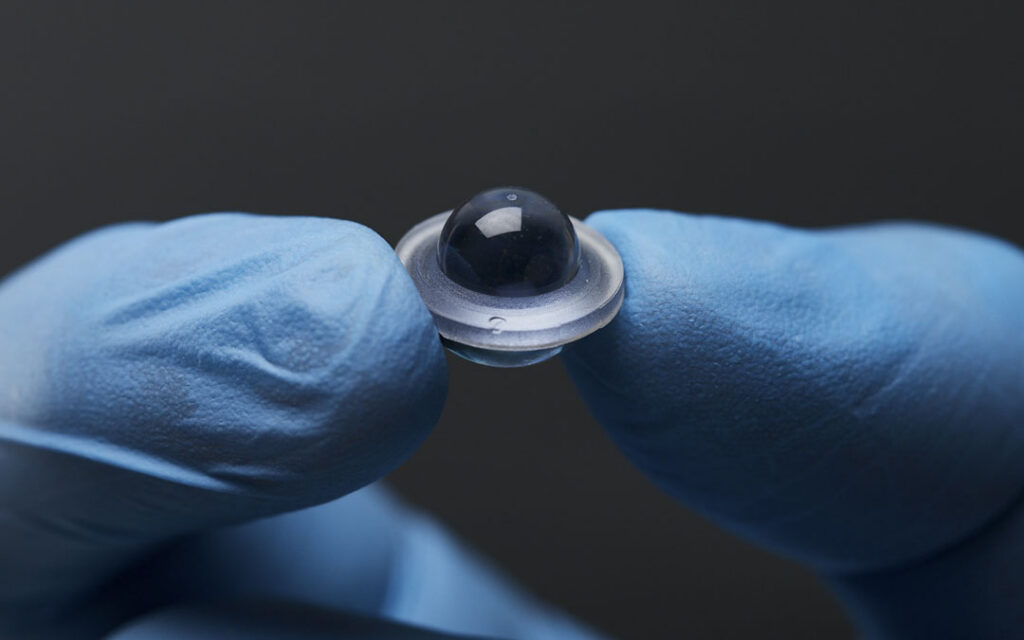
Passive sphere, Radix lens, active marker를 적용 환경에 맞춰 선택하면 오염 위험, 마커 가시성, 도구 설계, 수술 드레이핑 조건에 맞는 optical tracking workflow를 구성할 수 있습니다.
Polaris Vega 제품군은 hardware size, frame rate, latency, video integration, radiation hardening option 등에서 차이가 있습니다. 사용 환경과 OEM integration 요구사항에 따라 적합한 모델을 선택해야 합니다.
다양한 clinical environment와 research application에 적용하기 좋은 versatile optical tracker입니다. 60 Hz tracking, 17 ms typical latency, 0.12 mm RMS pyramid volumetric accuracy, optional extended measurement volume, optional radiation hardening을 통해 방사선 치료실이나 일반 연구실, OEM 내비게이션 장비 개발에 안정적으로 적용할 수 있습니다.
optical tracking과 integrated HD video를 함께 사용하는 모델입니다. tracker 좌표와 video image를 결합해야 하는 augmented reality, machine vision, image-guided visualization, OEM surgical navigation workflow에 적합합니다. tracker 자체의 3D tracking 데이터와 시각 정보를 함께 다루어야 하는 프로젝트에서 검토할 수 있습니다.
robotics와 high-speed navigation처럼 latency와 frame rate가 중요한 응용 분야를 위한 premium tracking 모델입니다. 최대 400 Hz frame rate와 sub-3 ms latency를 목표로 하는 responsive control workflow에서 검토할 수 있으며, 로봇 보조 장비, 고속 도구 추적, 동적 연구 시스템에 적합합니다.
광학식 3D 위치 추적 시스템의 성능은 tracker 사양뿐 아니라 marker visibility, line-of-sight, tool geometry, calibration, software diagnostics를 함께 관리해야 안정적으로 유지됩니다.
마커 좌표를 기반으로 tool의 3D position과 orientation을 계산합니다. 도구 끝점, rigid body, reference frame, patient 또는 phantom coordinate system을 연결해 공간 관계를 추적합니다.
frame rate와 latency 요구사항에 따라 ST, VT, XT 중 적합한 모델을 선택하고, 실시간 tracking data를 OEM host application으로 전송해 navigation과 control workflow에 사용합니다.

광학식 tracking은 marker visibility가 중요하므로 카메라 배치, 마커 각도, tool geometry, draping, 시야 가림 조건을 함께 검토해 안정적인 측정 환경을 설계합니다.

tool definition, system status, tracking volume, marker arrangement, calibration quality, communication status를 확인해 장기적인 tracking reliability와 QA workflow를 유지합니다.
아래 사양은 Polaris optical tracker comparison과 Polaris Vega ST technical specifications를 기준으로 정리했습니다. 프로젝트에 따라 model, volume option, marker type, tool design, software integration requirement를 함께 검토해야 합니다.
Pyramid / Extended Pyramid volume 기준 volumetric accuracy
일반 navigation과 research workflow에 적합한 measurement rates
60 Hz 기준 typical average latency
passive sphere와 active wireless tool 구성 지원
AR visualization과 machine vision workflow를 위한 video-enabled tracking
optical tracking과 video workflow 결합
Polaris Vega family comparison 기준
Polaris optical tracker comparison 기준
robotics와 high-speed navigation을 위한 premium tracking
responsive control workflow에 적합한 low latency
Pyramid / Extended Pyramid depth
OEM host application과 Ethernet 기반 data communication
Polaris는 일반 목적의 metrology instrument이며, 특정 의료 응용에 대한 적합성·인증·검증은 OEM 고객 또는 최종 사용자가 사용 목적과 규제 요구사항에 맞춰 확인해야 합니다.
Polaris Vega®는 optical marker를 기반으로 tool pose를 계산하기 때문에, 어떤 marker를 어떤 tool geometry로 배치할지와 tracking 시야 확보가 매우 중요합니다.
적외선을 반사하는 retro-reflective marker입니다. 설치가 간편하고 넓은 viewing angle을 제공하며, 비교적 오염 위험이 낮은 navigation workflow에서 많이 검토됩니다.
닦아낼 수 있는 lens marker로, 정형외과·척추·외상 수술처럼 오염 위험이 높거나 부분적인 occlusion이 발생할 수 있는 환경에서 안정적인 tracking workflow를 고려할 때 선택합니다.
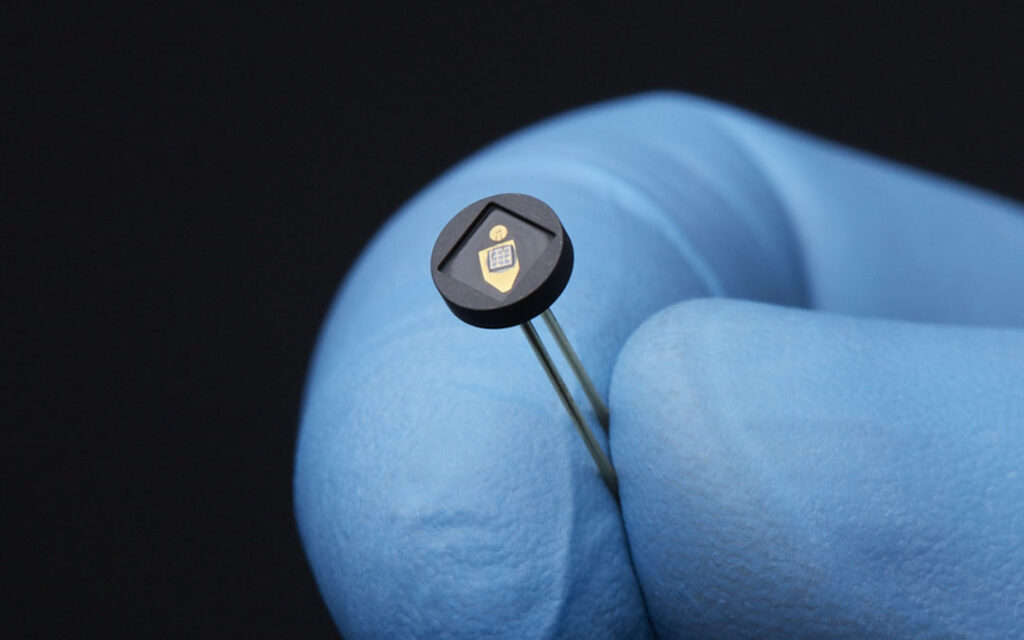
near-infrared LED 기반 active marker입니다. compact하고 low-profile 구조라 dynamic surgical robotic system, draping 아래 tracking, flexible tool design이 필요한 프로젝트에서 검토할 수 있습니다.
factory-calibrated probe, rigid body, clamps, mounting posts, passive spheres를 이용하면 custom tool을 빠르게 prototyping하고 Polaris optical tracker와의 tracking geometry를 검증할 수 있습니다.
Polaris Vega®는 정밀한 위치 기준과 실시간 tracking data가 필요한 수술 내비게이션, 로보틱스, 방사선 치료, 연구 장비 개발 환경에 활용됩니다.
probe, instrument, rigid body, reference frame을 추적해 cranial, spine, orthopaedic navigation과 OEM surgical system 개발에 필요한 공간 좌표를 제공합니다.
도구와 로봇 end-effector의 위치·방향을 빠르게 추적해 robotic-assisted workflow, high-speed navigation, responsive control 연구에 활용합니다.
optional radiation hardening과 stable optical tracking을 활용해 radiation therapy suite, patient positioning, respiratory motion monitoring 연구를 검토할 수 있습니다.
marker-based 3D tracking이 필요한 motion measurement, equipment validation, phantom experiment, coordinate registration 연구에 적용합니다.
tracking data를 OEM software와 연구 분석 환경에 통합해 tool pose, reference frame, calibration result를 확인합니다.
factory-calibrated tool 또는 custom rigid body를 이용해 실험과 장비 개발에 필요한 3D 기준점을 구성합니다.
상우과학은 Polaris Vega® 도입 시 단순 tracker 공급이 아니라, 실제 설치 환경과 연구·OEM 장비 목적에 맞춘 model selection, marker geometry, measurement volume, API integration, QA workflow를 함께 안내합니다.
general navigation, video-enabled workflow, robotics/high-speed tracking 중 목적을 정의하고 ST, VT, XT 중 적합한 Polaris Vega 모델을 선택합니다.
tracker와 대상 사이 거리, pyramid volume, extended volume, line-of-sight, 장비 고정 위치, 주변 조명과 occlusion 가능성을 검토합니다.
passive, Radix lens, active marker 중 선택하고, rigid body와 probe geometry, tool tip calibration, reference frame 구성을 설계합니다.
NDI API, Cygna 6D, ToolBox, Ethernet communication, QA procedure를 사용해 tracking data를 OEM software 또는 연구 분석 시스템에 통합합니다.
Polaris Vega®는 고성능 optical tracking에 특화되어 있으며, 공간 제약, line-of-sight, 소형 tracker 필요 여부에 따라 다른 NDI 제품과 함께 검토할 수 있습니다.
측정 목적, tracker 설치 공간, 필요한 frame rate와 latency, passive·active marker 사용 여부, tool geometry, OEM software integration, QA workflow를 알려주시면 적합한 Polaris Vega® 구성을 검토해드립니다.
전화 문의: 032-677-1880 · 이메일: info@sangwoosci.com